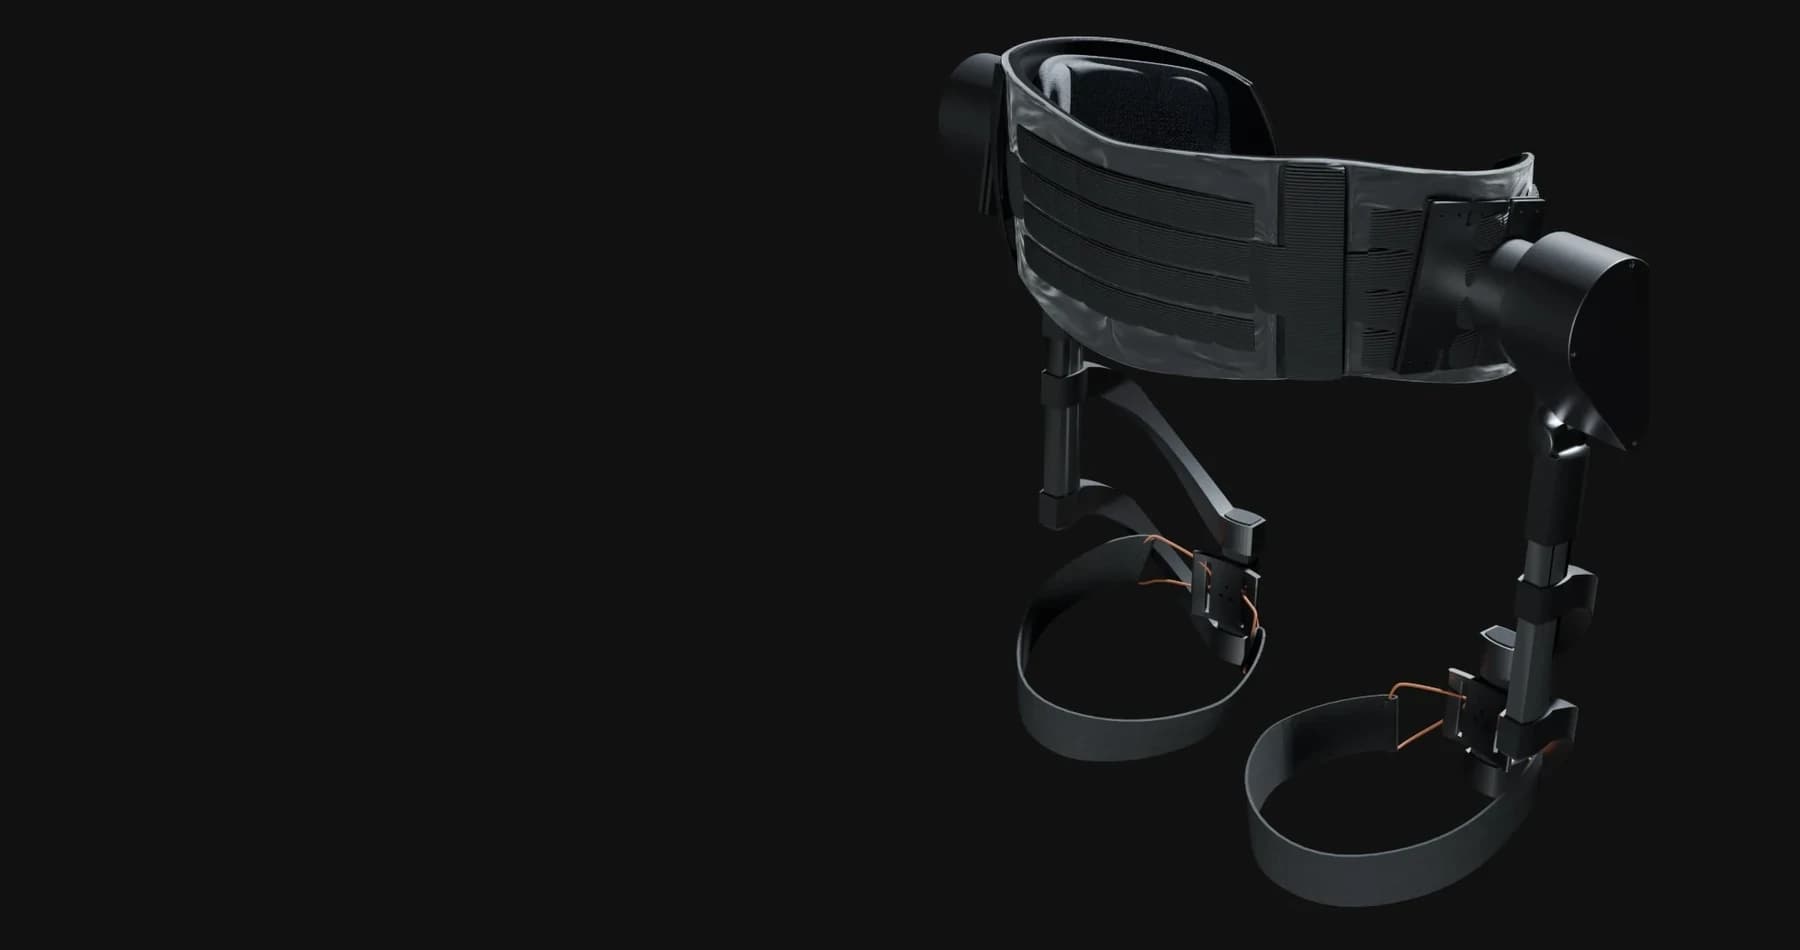
Programmable lower-limb exoskeleton for locomotion research. Open telemetry, controllable torque, transparent mode.
Built for biomechanics laboratories and the research arms of performance centres. Based in Colorado.
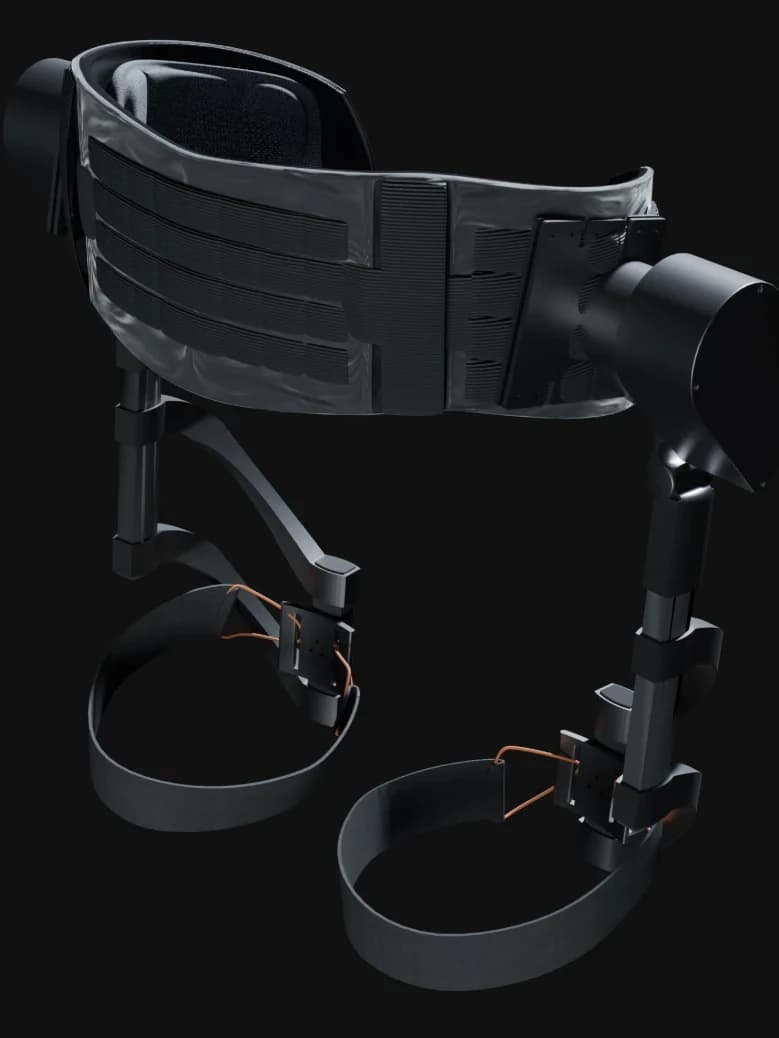
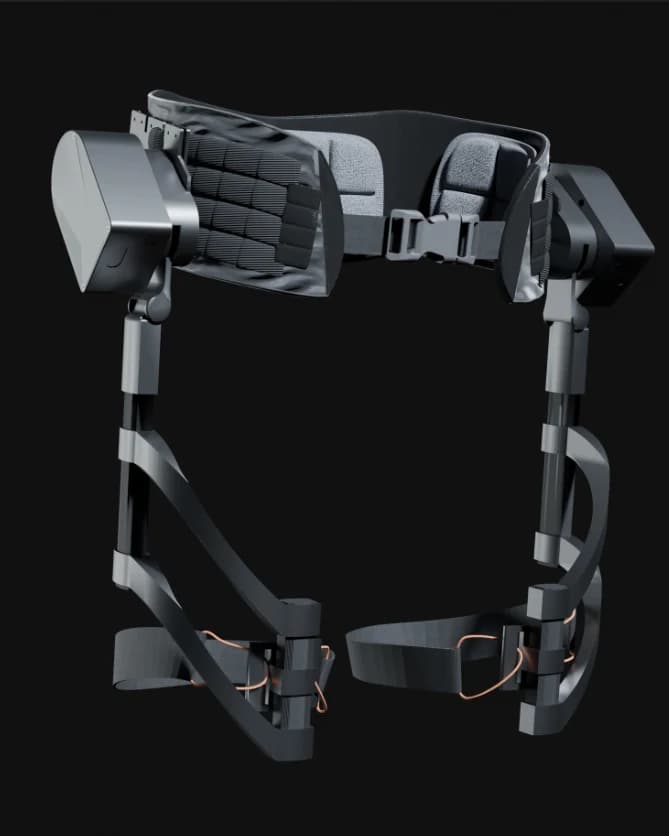
Torque you program
Assistance is a function you define across the gait cycle, not a preset you pick.
Data you own
Raw signals export in open formats. No closed ecosystem, no vendor dashboard between you and your data.
A true baseline
Transparent mode is built to track the limb with minimal resistance, so a session in the device is a usable control condition rather than a confound.
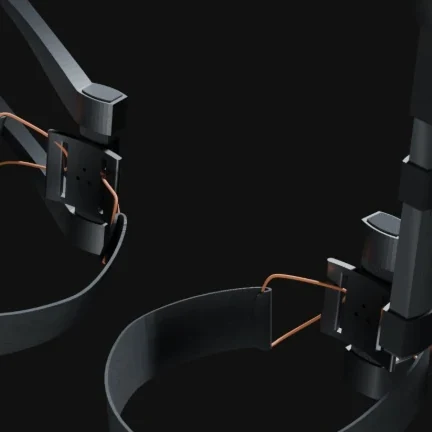
- 01
Sensing
Onboard sensors read joint state and interaction forces continuously, and every channel is logged.
- 02
Control
Torque profiles run on a real-time loop. Presets ship with the device; custom profiles are yours to write.
- 03
Actuation
Actuation at the hip, with commanded and measured torque both recorded. A knee module is in development and is not part of the current device.
- 04
Sync and export
Hardware trigger and timestamped streams for alignment with motion capture, force plates and EMG. Export as CSV and HDF5.
What laboratories are setting up with it. Photographs follow as the first sessions are recorded — we would rather show an empty row than a scene we staged.
- 01
Overground gait
Walking trials across a force-plate runway, in transparent mode and under assistance.
- 02
Incline and stairs
Controlled elevation work, where joint moments are highest.
- 03
Loaded locomotion
Carriage tasks with an added external load.
- 04
Sprint and change of direction
High-rate movement, where control latency is the limiting factor.
- 05
Extended-duration protocols
Multi-hour sessions for fatigue and metabolic work.
Peak and continuous torque, loop rate, latency, the telemetry schema, battery and the participant limits are all measured and written down. They are shared with laboratories considering an evaluation, in a document you can attach to a grant application — not published here.
What the document covers →We are placing units with biomechanics and performance laboratories. You design the protocol and own the data; we supply the instrument, the integration support and the engineering contact. Publications are yours.
Partnership programme →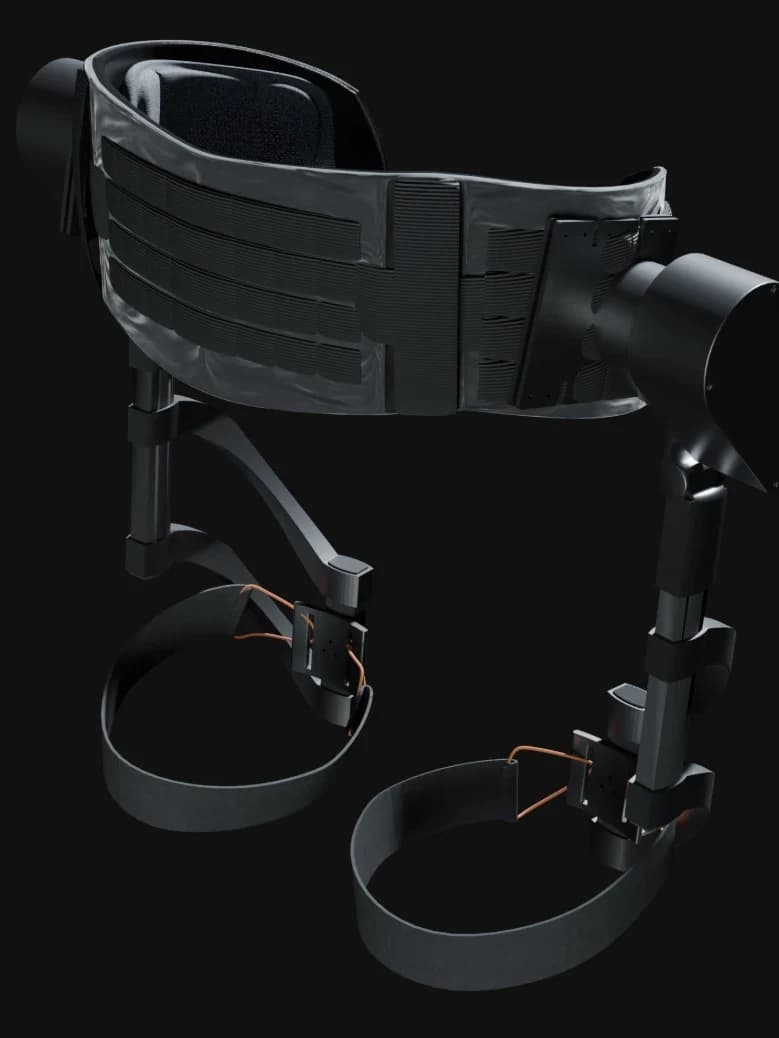
No. Dovmant is a research instrument. It is not cleared by the FDA and is not intended for diagnosis, treatment or prevention of any condition.
That is the intended use. The protocol, the IRB submission and the ethical oversight are the purchasing institution's responsibility. We supply the device specification and engineering support for your application.
Timestamped joint state, commanded and measured torque, and interaction forces, exported as CSV and HDF5. The full channel schema is in the specification we send you.
Tell us what you run. We check the trigger against your capture system before you commit to anything, and the systems it has been verified with are named in the specification we send you.
Yes. You define torque as a function of gait phase and load the profile onto the controller; the interface and the profile format are described in the specification.
Price, lead time and warranty are quoted to your institution in writing, in a form that goes straight into a grant budget. Ask and we will send it.
Yes. We provide the specification, a quotation and a letter of support for S10 and equivalent instrumentation funding.
Tell us what you study and what you run. We will work out whether the instrument fits your setup before you commit to anything.